Physical AI
Giving Robots a Human Sense of Touch and Body Awareness.
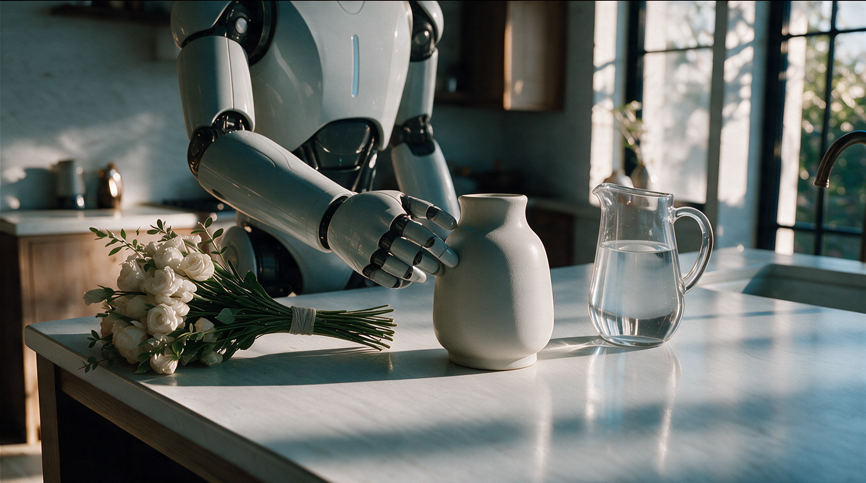
From a gentle touch to a firm grip.
Robots are now expected to handle more tasks, objects and environments, with both strength and precision. Yet conventional force sensors saturate under heavy loads and lose the sensitivity needed for light or fragile items. Robotics needs force sensing that stays accurate across the full operating range.
01
Wide sensing range
Measure heavy loads without saturating.
02
Sensitivity at every load
Detect fine interactions, even under strain.
03
Adaptive grip
Adjust force to each weight and shape.
04
Continuous feedback
Real-time contact data, not snapshots.
05
Precision & safety
Combine strength with delicate handling.
One technology, every form factor.
Fingers, grippers, hands or full-body skin: our sensors conform to complex geometries and integrate where your robot needs to feel.
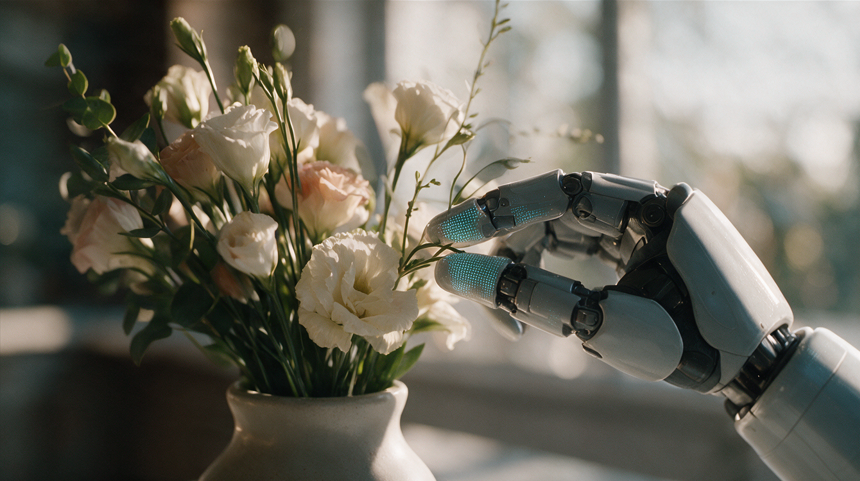
Fingers
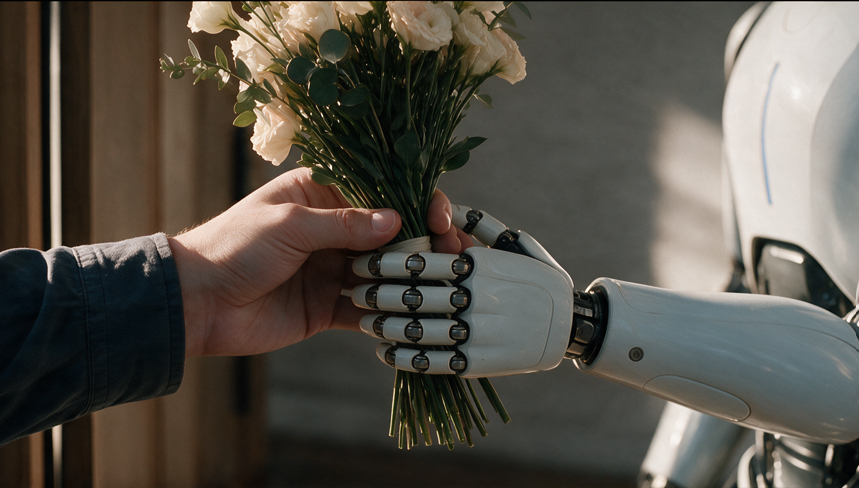
Grippers
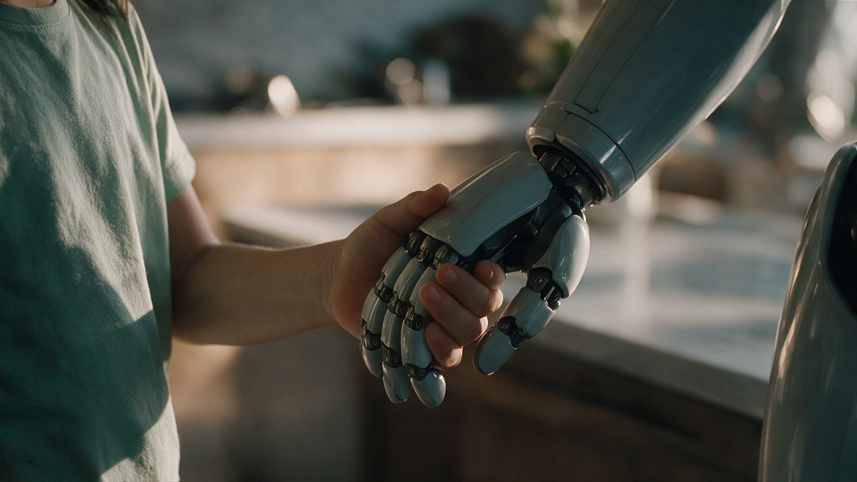
Hands
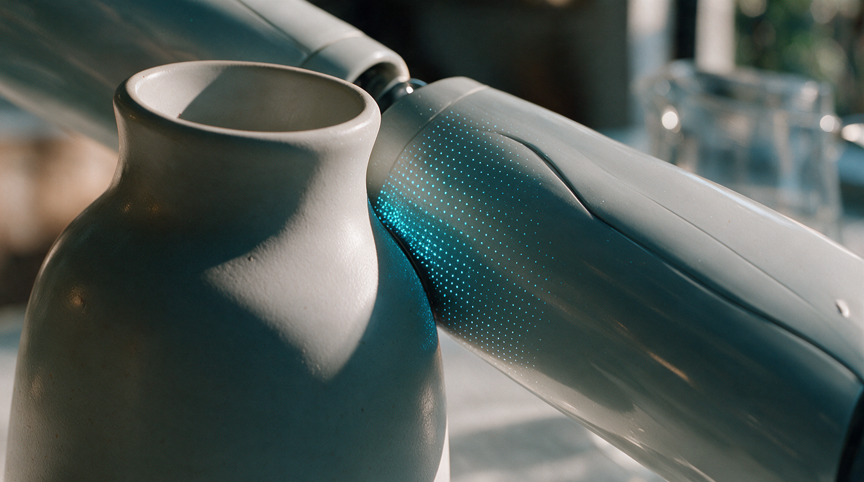
Tactile skin
Integration architecture
Nanomade sensors turn the robot’s structure into a sensing element. Deformation is captured where it happens, converted by dedicated electronics, processed into usable force and contact data, and delivered to the robot’s control system in real time, so it can adjust its behavior as it interacts with the physical world.
01
Sensor
02
Electronics
03
Signal processing
04
Robot system
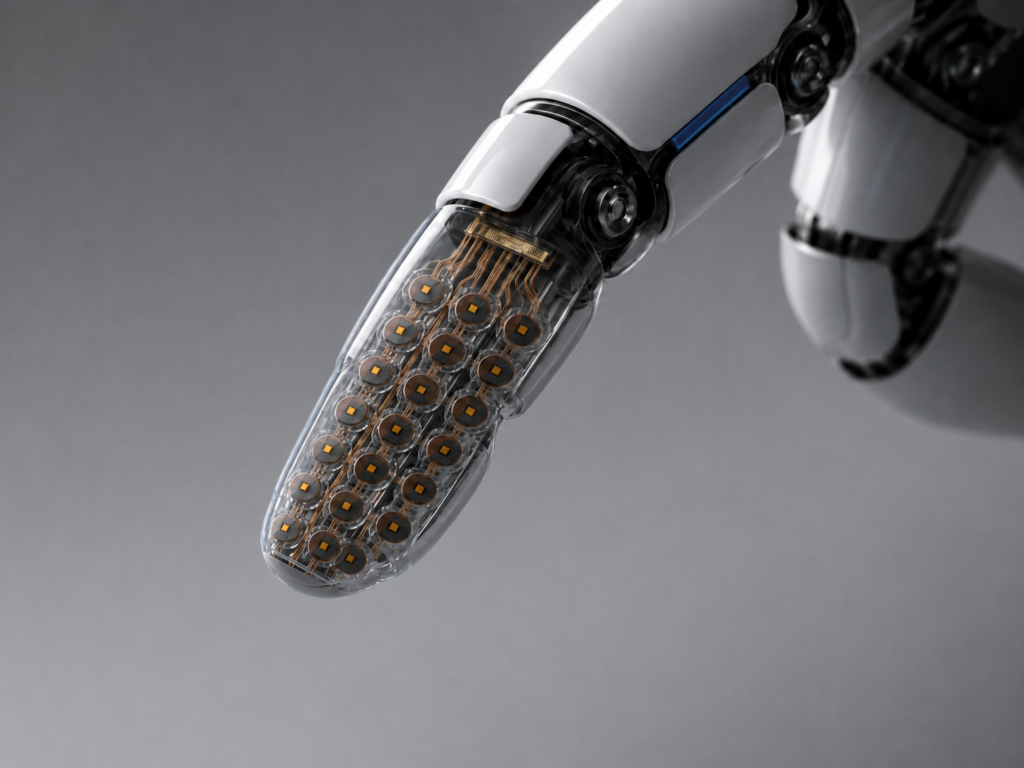
Adapt the sensor to the robot, not the opposite.
Thin and flexible, Nanomade sensors conform to fingers, grippers, wrists or joints, even on complex surfaces. They integrate directly into the robot’s structure, preserving its mechanical design while turning it into a sensing surface.
Have an application in mind?
Tell us about your product, your integration needs and the sensing capabilities you’re looking for.